MNV-H10 Series
MEMS GNSS/INS Integrated Navigation System
Product Overview
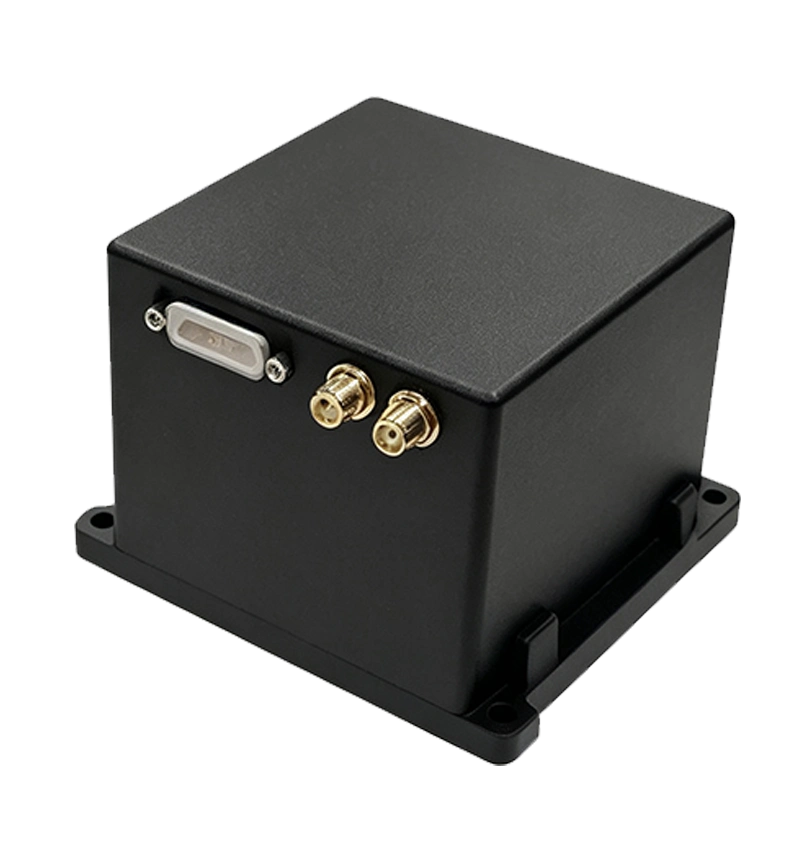
The MNV-H10 series is a high-performance MEMS GNSS/INS integrated navigation system. It integrates high-performance MEMS gyroscopes, MEMS accelerometers and GNSS satellite receiver chips. By sensing the earth's rotation angular rate and acceleration, it performs static self-alignment to obtain the true heading of the carrier. It implements integrated navigation by fusing 3D velocity, position and heading data acquired from the GNSS receiver, delivering reliable positioning and orientation for unmanned and mobile ground platforms.
Core Advantages
This MEMS GNSS/INS unit adopts high-performance, modular and lightweight design. Equipped with abundant interfaces and isolation protection. It supports full-band GNSS signals and RTK differential input, delivering high positioning and orientation accuracy under complex environments. Automatic north-seeking accuracy better than 1°.
Key Features for MEMS GNSS/INS
- High performance, modular structure, low weight
- Rich interfaces with isolation protection design
- Automatic north-seeking accuracy better than 1°
- Supports full-band GNSS, high accuracy in complex environments
- Compatible with RTK differential correction
Main Applications
- Vehicle positioning and attitude measurement
- Mobile mapping and surveying
- Unmanned ground vehicle navigation
- Optoelectronic stabilized platforms
- Dynamic attitude reference systems
Compare with our related inertial navigation unit: MNV-H15 MEMS INS Navigation System
Learn about MEMS inertial sensor fundamentals: Bosch MEMS inertial technology
Performance Specifications
| Category | Parameter Item | MNV‑H10NA | MNV‑H10NB | MNV‑H10NC | MNV‑H10A | MNV‑H10B | MNV‑H10C |
|---|---|---|---|---|---|---|---|
| Gyroscope | Range (°/s) | ±300 | ±200 | ±400 | ±400 | ±400 | ±500 |
| Full-temperature Bias (°/h, 3σ) | ≤ 0.1 | ≤ 0.3 | ≤ 2 | ≤ 10 | ≤ 80 | ≤ 60 | |
| Bias Stability (°/h, 10s Smooth) | ≤ 0.1 | ≤ 0.1 | ≤ 0.5 | ≤ 1 | ≤ 3 | ≤ 5 | |
| Scale Factor Nonlinearity (ppm) | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | |
| Accelerometer | Range (g) | ±10 | ±10 | ±30 | ±30 | ±20 | ±40 |
| Full-temperature Bias (mg, 3σ) | ≤ 0.2 | ≤ 0.5 | ≤ 2 | ≤ 2 | ≤ 2 | ≤ 3 | |
| Bias Stability (μg, 10s Smooth) | ≤ 20 | ≤ 20 | ≤ 50 | ≤ 50 | ≤ 50 | ≤ 100 | |
| Scale Factor Nonlinearity (ppm) | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | ≤ 100 | |
| Navigation Accuracy | North-seeking Accuracy (°,1σ) | ≤ 0.5 | ≤ 0.5 | ≤ 3 | / | / | / |
| Pure Inertial Accuracy (1σ,60s) | ≤1m/60s | ≤3m/60s | ≤5m/60s | ≤5m/60s | ≤10m/60s | ≤20m/60s | |
| Horizontal Position (m,1σ) | ≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤2 (Single) ≤0.02+1ppm (RTK) |
≤3 (Single) ≤0.02+1ppm (RTK) |
|
| Vertical Position (m,1σ) | ≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤3 (Single) ≤0.03+1ppm (RTK) |
≤5 (Single) ≤0.03+1ppm (RTK) |
|
| Horizontal Velocity (m/s,1σ) | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.05 | ≤0.1 | |
| Vertical Velocity (m/s,1σ) | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.1 | ≤0.15 | |
| Combined Heading (°,1σ) | ≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.15 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.2 (Single, dynamic) |
≤0.1 (2m baseline dual-antenna) ≤0.2 (Single, dynamic) |
≤0.15 (2m baseline dual-antenna) ≤0.5 (Single, dynamic) |
|
| Horizontal Attitude (°,1σ) | ≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.015 (Single, dynamic) ≤0.01 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
≤0.05 (Single, dynamic) ≤0.03 (RTK, dynamic) |
|
| Physical Characteristics | Power Supply (V) | 9~36 | 9~36 | 9~36 | 9~36 | 9~36 | 9~36 |
| Steady-state Power (W) | ≤4 | ≤4 | ≤4 | ≤4 | ≤4 | ≤4 | |
| Start-up Time (s) | ≤2 | ≤2 | ≤2 | ≤2 | ≤2 | ≤2 | |
| Update Rate (Hz, max) | 200 | 200 | 200 | 200 | 200 | 200 | |
| Dimension (mm×mm×mm) | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | 70×66×63 | |
| Weight (g) | ≤370 | ≤370 | ≤370 | ≤370 | ≤370 | ≤370 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | -55 ~ +85 | |
| Vibration (g, RMS) | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | 20~2000, 6.06 | |
| Shock (g) | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms | 500g/1ms |
This MEMS GNSS/INS integrated navigation system is built for long-duration mobile positioning tasks. Its tightly-coupled fusion algorithm maintains stable output when GNSS signals degrade or are blocked. With built-in north-seeking capability and RTK support, the MNV-H10 series is a reliable all-weather navigation solution for ground unmanned platforms, survey vehicles and optoelectronic payloads.