MIU-BA50
MEMS Inertial Measurement Unit
Product Overview
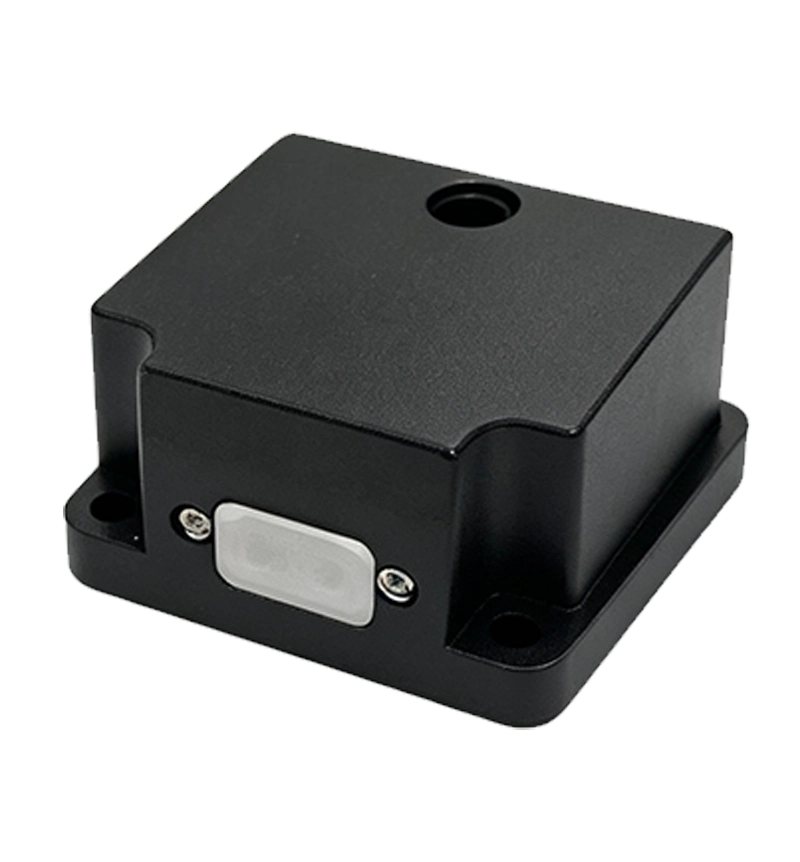
MIU-BA50 is a highly reliable and cost-effective six-axis high-precision inertial sensor. This compact MEMS IMU delivers stable raw sensing data, widely used in inertial navigation, attitude stabilization, flight control and precision measurement for unmanned platforms.
Core Advantages
This inertial sensor features high performance, small size, light weight and low power consumption. It supports -45℃ ~ +80℃ full-temperature calibration compensation, multi-sensor redundancy and fault-tolerant design, online firmware upgrade, and withstands harsh mechanical environments. With 100% domestic components and high-speed sampling, it is a cost-effective choice for UAV inertial navigation projects.
Key Features of MIU-BA50 inertial sensor
- High performance, small size, light weight and low power consumption
- -45℃ ~ +80℃ full-temperature calibration compensation
- Multi-sensor redundancy and fault-tolerant design
- Support software online upgrade
- Resist harsh mechanical environments
- High-speed sampling up to 2000Hz
- Cost-effective with fully domestic components
Main Applications
- Inertial navigation and attitude stabilization
- UAV flight control & inertial navigation
- Unmanned vehicle and marine attitude measurement
- Precision motion measurement
- High dynamic inertial measurement
Compare with our MIU-BA20 inertial sensor to select the proper IMU for your system.
Performance Specifications
| Category | Parameter Item | MIU-BA50 |
|---|---|---|
| Gyroscope | Range (°/s) | ±300 |
| Full-temperature Bias (°/h, 3σ) | ≤80 | |
| Bias Stability (°/h, 10s smoothing) | ≤3 | |
| Bias Stability (°/h, allan) | ≤0.5 | |
| Bias Repeatability (°/h) | ≤3 | |
| Angular Random Walk (°/√h) | ≤0.025 | |
| Scale Factor Nonlinearity (ppm) | ≤100 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Accelerometer | Range (g) | ±20 |
| Full-temperature Bias (mg, 3σ) | ≤2 | |
| Bias Stability (μg, 10s smoothing) | ≤50 | |
| Bias Stability (μg, allan) | ≤30 | |
| Bias Repeatability (μg) | ≤50 | |
| Velocity Random Walk (m/s/√h) | ≤0.04 | |
| Scale Factor Nonlinearity (ppm, ±1g) | ≤100 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Physical Characteristics | Power Supply (V) | 5~12 |
| Steady-state Power (W) | ≤1 | |
| Start-up Time (s) | ≤2 | |
| Update Rate (Hz, max) | 2000 | |
| Dimension (mm×mm×mm) | 44.8×38.6×21.5 | |
| Weight (g) | ≤52 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 20~2000Hz, 6.06 | |
| Shock (g) | 1000/1ms |
This inertial sensor outputs synchronized gyro and accelerometer raw data for navigation algorithm development. It works well paired with GNSS and RTK modules for combined navigation solutions. We provide full datasheet, communication protocol and technical support for system integration and bulk procurement.