MAH-A501
MEMS AHRS
Product Overview of MAH-A501 MEMS AHRS
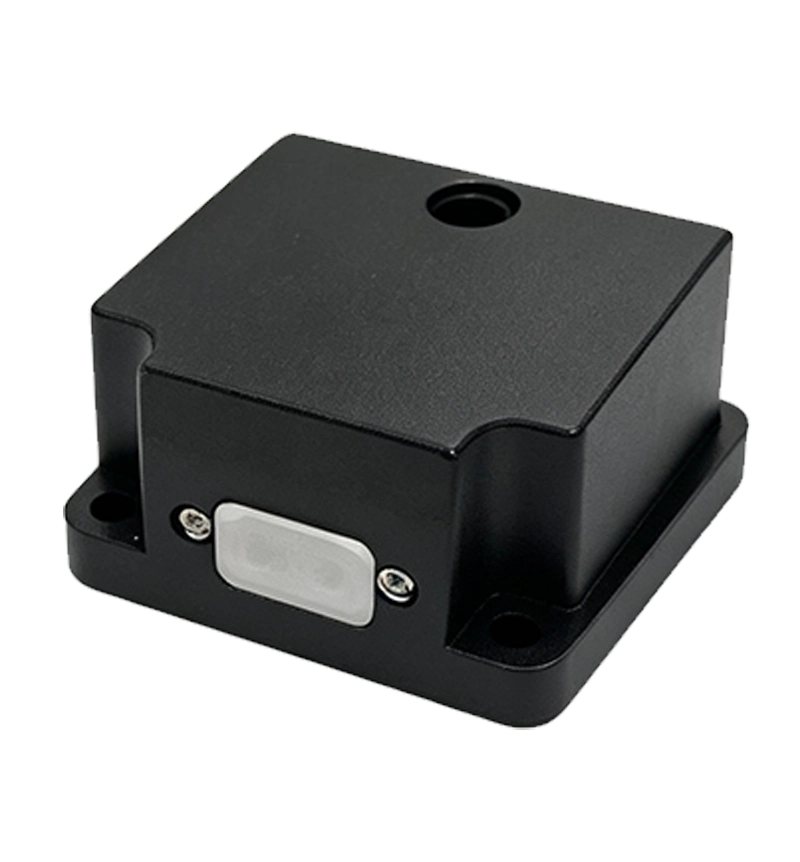
MAH-A501 is a high-dynamic, high-reliability and cost-effective 6-axis MEMS inertial attitude heading reference system. The module implements full-temperature compensation for bias, scale factor, non-orthogonality error and acceleration-related terms to maintain high measurement accuracy over long durations. Adopting integral vibration damping and hermetic sealing design, it is widely applied in navigation, control and measurement domains including satellites, vehicles, ships and UAVs.
Built for unmanned platforms, this compact unit delivers stable attitude output even under complicated dynamic motion. Its built-in compensation algorithm eliminates temperature drift errors across the full working range, removing the requirement for frequent on-site recalibration for most integration projects. Engineers can directly feed its attitude, heading and angular rate data into flight controllers, vehicle navigation units and stabilization servo systems.
Core Advantages of this MEMS AHRS
Full-temperature calibration compensation from -45℃ to +80℃, compact size, light weight and low power consumption. Integrated adaptive attitude algorithm, supports 1kHz high-speed sampling and features robust performance under harsh mechanical environments. It supports multiple industrial serial interfaces for seamless integration with mainstream autopilot and navigation hardware.
Key Features of the MEMS AHRS
- -45℃ ~ +80℃ full-temperature calibration & compensation
- Small size, light weight and low power consumption
- Adaptive attitude heading algorithm for stable output
- 1kHz high-speed sampling
- Resistant to harsh mechanical environments, vibration and shock
Main Applications for this AHRS
- UAV attitude measurement & control
- Vehicle & ship navigation
- Satellite-borne motion sensing
- Platform stabilization systems
- Industrial dynamic attitude monitoring
Compare with our other model: CW-AHRSS3330 MEMS AHRS for your project selection.
Performance Specifications of MAH-A501 AHRS
| Category | Parameter Item | MAH-A501 |
|---|---|---|
| Gyroscope | Range (°/s) | ±500 |
| Full-temperature Bias (°/h) | ≤ 3 | |
| Bias Stability (°/h, 10s smooth) | ≤ 0.3 | |
| Bias Repeatability (°/h) | ≤ 0.3 | |
| Angular Random Walk (°/√h) | ≤ 0.05 | |
| Scale Factor Nonlinearity (ppm) | ≤ 150 | |
| Threshold / Resolution (°/h) | ≤ 3 | |
| Bandwidth (Hz) | 200 | |
| Accelerometer | Range (g) | ±30 |
| Full-temperature Bias (mg) | ≤ 2 | |
| Bias Stability (μg, 10s smooth) | ≤ 100 | |
| Bias Repeatability (μg) | ≤ 100 | |
| Scale Factor Nonlinearity (ppm) | ≤ 500 | |
| Threshold / Resolution (μg) | ≤ 50 | |
| Bandwidth (Hz) | 150, adjustable | |
| AHRS System | Pitch Measurement Range (°) | ±90 |
| Roll Measurement Range (°) | ±180 | |
| Attitude Accuracy (°, RMS) | Steady-state ≤0.1; Low dynamic ≤0.5 | |
| Electrical & Mechanical Interface | Power Supply (V) | 5-12 |
| Power Consumption (W) | 1.5 | |
| Start-up Time (s) | 2 | |
| Communication Interface | RS-422/RS-232/PPS_IN/TOV | |
| Update Rate (Hz) | 200 (Configurable, up to 1kHz) | |
| Dimension (mm×mm×mm) | 44.8×38.6×21.5 | |
| Weight (g) | ≤ 55 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 6.06 | |
| Shock (g) | 1000g/1ms (Power-on) |
For theory of attitude heading reference system, you can refer to technical resources on inertial sensing standards IEEE Xplore.