MNF-N205
MEMS North Seeker
Product Overview
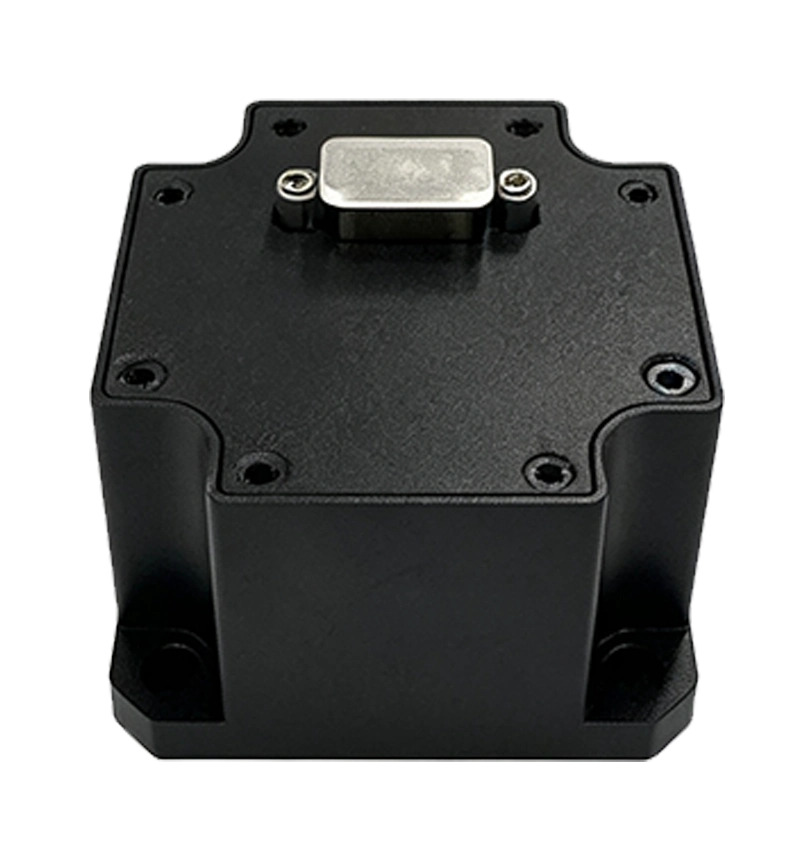
MNF-N205 MEMS North Seeker is a high-reliability, cost-effective six-axis MEMS inertial sensor. The module internally compensates full-temperature parameters including zero bias, scale factor, non-orthogonality error and acceleration-related terms, maintaining high measurement accuracy for a long time. Adopting integral vibration reduction and sealing design, this MEMS north finder is widely applied in navigation, control and measurement fields represented by inertial navigation and attitude stabilization.
Why Choose This MEMS North Seeker
High performance, compact size, light weight and low power consumption. Full-temperature calibration and compensation from -45℃ to +80℃. Supports automatic zero-speed correction to maintain stable azimuth accuracy. Supports component zero-bias calibration function. 100% domestically sourced components. 4kHz high-speed sampling. It can reliably work under harsh mechanical environments with strong vibration and shock.
Key Features of the MEMS North Seeker
- High performance, compact size, light weight, low power consumption
- -45℃ ~ +80℃ full-temperature calibration & compensation
- Supports automatic zero-speed correction for azimuth accuracy retention
- Supports component zero-bias calibration function
- 4kHz high-speed sampling
- Resistant to harsh mechanical environments
Main Applications
- Inertial navigation and attitude stabilization
- Azimuth determination & true north seeking
- Platform attitude measurement and pointing
- UAV and unmanned vehicle navigation control systems
- Precision industrial dynamic measurement
Compare with our other inertial sensors: MAH-A301 MEMS AHRS to select the right inertial sensing solution for your project.
Performance Specifications
| Category | Parameter Item | MNF-N205 |
|---|---|---|
| Gyroscope | Range (°/s) | 200 |
| Zero Bias (°/h) | 0.1 | |
| Bias Stability (°/h, 10s smooth) | 0.1 | |
| Bias Repeatability (°/h) | 0.1 | |
| Scale Factor Nonlinearity (ppm) | 100 | |
| Bandwidth (Hz) | 50 | |
| Accelerometer | Range (g) | 20 |
| Zero Bias (mg) | 1 | |
| Bias Stability (μg) | 100 | |
| Bias Repeatability (μg) | 100(1σ) | |
| Scale Factor Nonlinearity (ppm) | 500(1σ) | |
| Bandwidth (Hz) | 100 | |
| Attitude & North-Seeking Accuracy | North-seeking Azimuth Accuracy (°,5min,1σ) | 0.5*sec(L) (L = Latitude) |
| North-seeking Horizontal Attitude Accuracy (°,5min,1σ) | 0.15 | |
| Heading Hold Accuracy (°/h,1σ) | 0.5°/h | |
| Horizontal Attitude Hold Accuracy (°,1σ) | 0.2°/h | |
| Electrical & Mechanical Interface | Power Supply (V) | 5±0.2 |
| Power Consumption (W) | ≤ 2 | |
| Start-up Time (s) | ≤ 2 | |
| Communication Interface | 2 × RS-422, or 1 × RS-422 + 1 × synchronous output | |
| Update Rate (Hz) | 200 | |
| Dimension (mm×mm×mm) | 47×47×28 | |
| Weight (g) | ≤ 200 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 6.06 | |
| Shock (g) | 1000g/1ms (powered on) | |
| MTBF (h) | 200000 |
This compact MEMS North Seeker outputs true north azimuth without GNSS signals. It provides stable heading reference for unmanned platforms before mission initialization. With flexible RS-422 serial output, it can be quickly integrated with onboard flight controllers and navigation computers for north alignment and azimuth calibration.