MIU-B01A
MEMS Inertial Measurement Unit
Product Overview
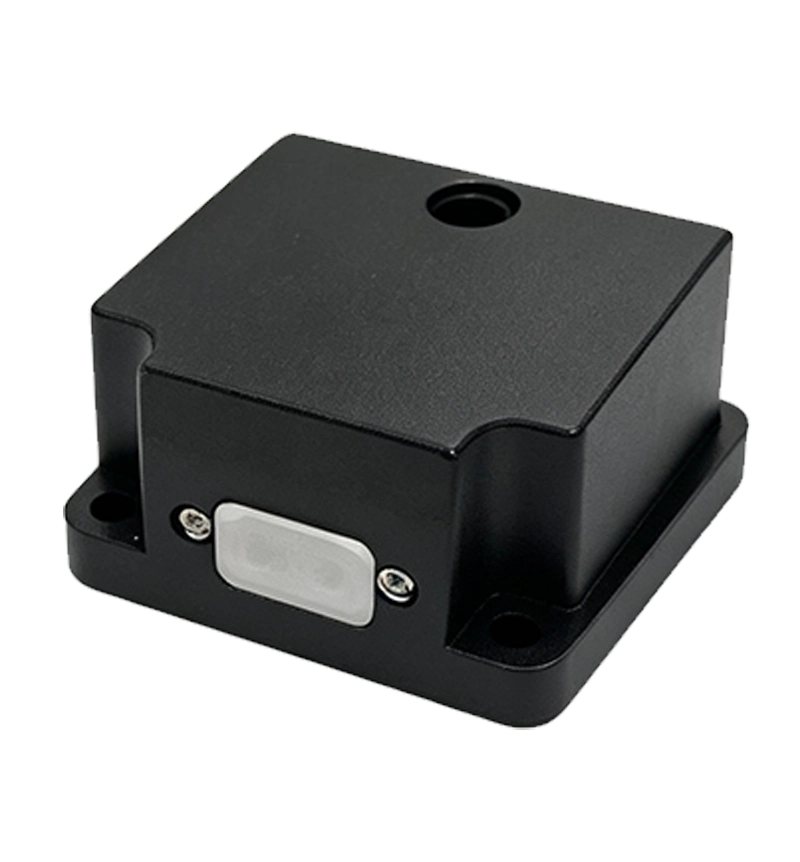
A MEMS IMU serves as the core inertial sensing component for motion and attitude measurement. Our MIU-B01A unit is a highly reliable and cost-effective six-axis high-precision MEMS inertial sensor. It is widely adopted for inertial navigation, attitude stabilization, closed-loop control and precision measurement on unmanned platforms.
Core Advantages
High performance, compact size, light weight and low power consumption; -45℃ ~ +80℃ full-temperature calibration compensation; multi-sensor redundancy and fault-tolerant design; support online firmware upgrade; withstand harsh vibration and shock environments; 100% domestically manufactured; high-speed sampling up to 1000Hz.
MEMS IMU Key Features
- High performance, compact size, light weight, low power consumption
- Full temperature calibration compensation from -45℃ to +80℃
- Multi-sensor redundancy and fault-tolerant architecture
- Support online firmware upgrade
- High resistance to harsh mechanical vibration & shock
- 100% domestically manufactured components
- High-speed sampling, max 1000Hz update rate
Main Applications
- Inertial navigation and attitude stabilization systems
- UAV flight control and navigation payload
- UGV / USV vehicle and marine attitude measurement
- Optoelectronic platform stabilization & precision motion measurement
- High-dynamic inertial measurement scenarios
Related product: MNV-H10 MEMS GNSS/INS Navigation System
Reference: Bosch MEMS inertial sensor technology
Performance Specifications
| Category | Parameter Item | MIU-B01A |
|---|---|---|
| Gyroscope | Range (°/s) | ±500 |
| Full-temperature Bias (°/h, 3σ) | ≤100 | |
| Bias Stability (°/h, 10s smoothing) | ≤5 | |
| Bias Instability (°/h, allan, typ) | ≤1 | |
| Bias Repeatability (°/h) | ≤5 | |
| Angular Random Walk (°/√h) | ≤0.1 | |
| Scale Factor Non-linearity (ppm) | ≤100 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Accelerometer | Range (g) | ±16 |
| Full-temperature Bias (mg, 3σ) | ≤3 | |
| Bias Stability (μg, 10s smoothing) | ≤100 | |
| Bias Instability (μg, allan) | ≤30 | |
| Bias Repeatability (μg) | ≤50 | |
| Velocity Random Walk (m/s/√h) | ≤0.03 | |
| Scale Factor Non-linearity (ppm, ±1g) | ≤200 | |
| Cross-coupling (rad) | ≤0.001 | |
| Bandwidth (Hz) | ≥200 | |
| Physical Characteristics | Power Supply (V) | 5~12 |
| Steady-state Power (W) | ≤1 | |
| Start-up Time (s) | ≤2 | |
| Update Rate (Hz, max) | 1000 | |
| Dimension (mm×mm×mm) | 44.8×38.6×21.5 | |
| Weight (g) | ≤52 | |
| Operating Environment | Operating Temperature (℃) | -45 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 20~2000Hz, 6.06 | |
| Shock (g) | 1000/1ms |
This compact inertial measurement unit delivers clean gyro and accelerometer raw data for downstream navigation integration. With excellent Allan variance performance and strong environmental adaptability, it is widely selected by system integrators as the core sensing unit for custom GNSS/INS, stabilized payload and unmanned motion measurement solutions. It can be easily embedded into small unmanned platforms where space and power budget are strictly limited.