MAH-A502
MEMS AHRS
Product Overview
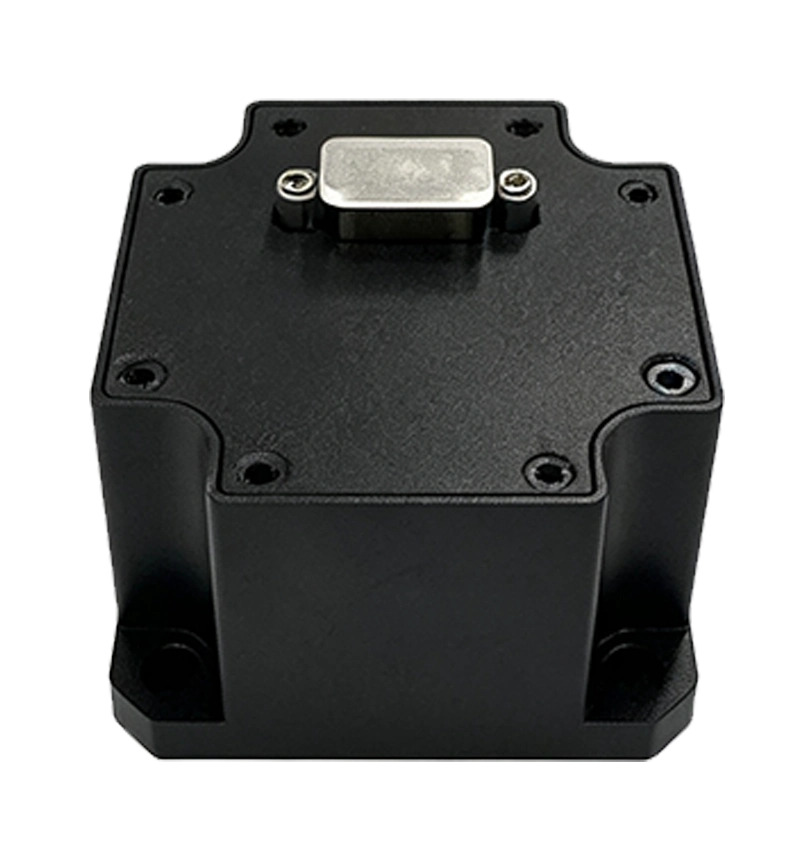
MAH-A502 is a high-reliability, cost-effective 6-axis MEMS attitude heading reference system. This AHRS module adopts comprehensive full-temperature compensation covering bias, scale factor, non-orthogonality error and acceleration-related terms, sustaining stable and precise measurement over long operating periods. Integrated vibration damping and hermetic sealing enable consistent attitude output for UAV, vehicle, marine and satellite-borne control and measurement systems.
Core Advantages
It supports full-temperature calibration across -40℃ to +80℃ with compact footprint, lightweight design and low power draw. Powered by an adaptive attitude heading algorithm, the unit runs 1kHz high-speed sampling and maintains dependable performance under severe vibration and shock, which are common working conditions for unmanned vehicles and motion stabilization platforms.
Key Features
- -40℃ ~ +80℃ full-temperature calibration & compensation
- Small size, light weight and low power consumption
- Adaptive attitude heading algorithm
- 1kHz high-speed sampling, configurable output rate
- Robust mechanical structure for harsh vibration and shock
Typical Applications
- UAV attitude measurement & flight autopilot control
- Ground vehicle and marine inertial attitude sensing
- Satellite-borne motion state monitoring
- Optical and antenna stabilization platform feedback
- Industrial dynamic attitude monitoring
Compare with our sister model: MAH-A501 MEMS AHRS to select the proper inertial sensing solution.
Performance Specifications
| Category | Parameter Item | MAH-A502 |
|---|---|---|
| Gyroscope | Range (°/s) | ±500 |
| Full-temperature Bias (°/h) | ≤ 30 | |
| Bias Stability (°/h, 10s smooth) | ≤ 5 | |
| Bias Stability (°/h, allan, typ) | 0.5 | |
| Bias Repeatability (°/h) | ≤ 3 | |
| Angular Random Walk (°/√h) | ≤ 0.3 | |
| Scale Factor Nonlinearity (ppm) | ≤ 150 | |
| Bandwidth (Hz) | 200 | |
| Accelerometer | Range (g) | ±50 |
| Full-temperature Bias (mg) | ≤ 3 (XY); ≤ 5 (Z) | |
| Bias Stability (μg, 10s smooth) | ≤ 100 | |
| Bias Stability (μg, allan) | ≤ 30 | |
| Bias Repeatability (μg) | ≤ 300 | |
| Velocity Random Walk (mm/s/√h) | ≤ 40 | |
| Scale Factor Nonlinearity (ppm) | ≤ 500 | |
| Bandwidth (Hz) | 150, adjustable | |
| AHRS System | Pitch Measurement Range (°) | ±90 |
| Roll Measurement Range (°) | ±180 | |
| Attitude Accuracy (°, RMS) | Steady-state ≤0.2; Dynamic ≤2 | |
| Electrical & Mechanical Interface | Power Supply (V) | 5-12 |
| Power Consumption (W) | 1.5 | |
| Start-up Time (s) | 2 | |
| Communication Interface | 1×RS-422, 2×RS-232, 1×Sync TTL Output, 1×Sync TTL Input | |
| Update Rate (Hz) | 200 (Configurable, up to 1kHz) | |
| Dimension (mm×mm×mm) | 47×47×28 | |
| Weight (g) | ≤ 200 | |
| Operating Environment | Operating Temperature (℃) | -40 ~ +80 |
| Storage Temperature (℃) | -55 ~ +85 | |
| Vibration (g, RMS) | 6.06 | |
| Shock (g) | 1000g/1ms (Power-on) |
This compact MEMS AHRS continuously outputs roll, pitch and heading data for autopilot loops and stabilization control. It delivers stable attitude feedback when GNSS signals degrade or become unavailable, which is critical for unmanned platforms that cannot rely on satellite navigation alone. The flexible serial protocol design simplifies integration with onboard flight controllers and embedded navigation computers. We also provide technical support, protocol documentation and custom calibration services for volume integration projects.